Maciej K. Wozniak

Zenseact
Gothenburg / Stockholm, Sweden
I am a Senior Deep Learning Researcher at Zenseact, working on perception and planning for autonomous driving, where I also supervise PhD student Adam Rokah. I joined Zenseact in May 2026 and received my Ph.D. from KTH Royal Institute of Technology in 2026 with the thesis Look Ma, No Labels: From Robust Perception to Self-Supervised Representation Learning for Autonomous Driving, supervised by Patric Jensfelt and André Pereira. My doctoral studies were supported by the Wallenberg AI, Autonomous Systems and Software Program (WASP). During my Ph.D. I also interned at Qualcomm and was selected as an ACM/IEEE HRI Pioneer.
My research focuses on 3D computer vision and deep learning for robot perception — including self-supervised pre-training and distillation of foundation models into LiDAR backbones, domain adaptation, end-to-end planning, and diffusion models for driving. I also build VR/AR frameworks for human-robot interaction.
Find me on Google Scholar, GitHub, and LinkedIn.
news
| Oct 20, 2026 | PRIX (RA-L) was presented at IROS 2026. |
|---|---|
| Oct 16, 2026 | I defended my PhD thesis Look Ma, No Labels: From Robust Perception to Self-Supervised Representation Learning for Autonomous Driving at KTH! Huge thanks to my opponent Andrei Bursuc (Valeo.ai) and my supervisors Patric Jensfelt and André Pereira. |
| Sep 4, 2026 | One Diffusion Model, Two Roles, on guided trajectory planning and safety-critical scenario generation, master thesis project done by my students at Zenseact accepted at an ECCV 2026 workshop. |
| Sep 1, 2026 | I started supervising Adam Rokah, a PhD student at Zenseact. |
| Jun 18, 2026 | HilDA: Hierarchical Distillation with Diffusion for self-supervised LiDAR pre-training accepted to ECCV 2026! Code: KTH-RPL/HilDA. |
| May 1, 2026 | I joined Zenseact as a Senior Deep Learning Researcher, working on perception and planning for autonomous driving. |
| Oct 28, 2025 | BlendCLIP on zero-shot 3D object classification accepted to WACV 2026! |
| Aug 11, 2025 | CleverDistiller was accepted to BMVC 25 (~25% acceptance rate). |
| May 1, 2025 | I gave a talk on ‘‘Self – supervised learning for autonomous driving perception’’ to different teams at Qualcomm, zenseact and Scania! Slides available here. |
| Mar 31, 2025 | Check out CleverDistiller our work on distilling camera VFM to LiDAR networks! |
| Mar 1, 2025 | I defended 50% of my PhD. Thanks Holger Caesar for great discussion! |
| Oct 1, 2024 | Our work on VFM for Autonomous Driving (S3PT) accepted to WACV as Oral presentation |
| Sep 1, 2024 | UADA accepted to RA-L ‘24Unsupervised Adversarial Domain Adaptaion for 3D Object Detection (UADA3D). |
| Jun 1, 2024 | I started an internship at Qualcomm on Multimodal Self-Supervised Learning for Autonomous Driving Perception. |
| Feb 1, 2024 | Check our project on Unsupervised Adversarial Domain Adaptaion for 3D Object Detection (UADA3D). |
| Jan 8, 2024 | Happy to announce that I was chosen as ACM/IEEE HRI Pioneer! See you in Boulder in March! |
| Dec 27, 2023 | Check our VAM-HRI workshop! |
| Dec 1, 2023 | I participed and gave a presentation during WARA M&L days in Are! |
selected publications
- PhDLook Ma, No Labels: From Robust Perception to Self-Supervised Representation Learning for Autonomous DrivingKTH Royal Institute of Technology, 2026Doctoral thesis. Opponent: Andrei Bursuc (Valeo.ai)
-
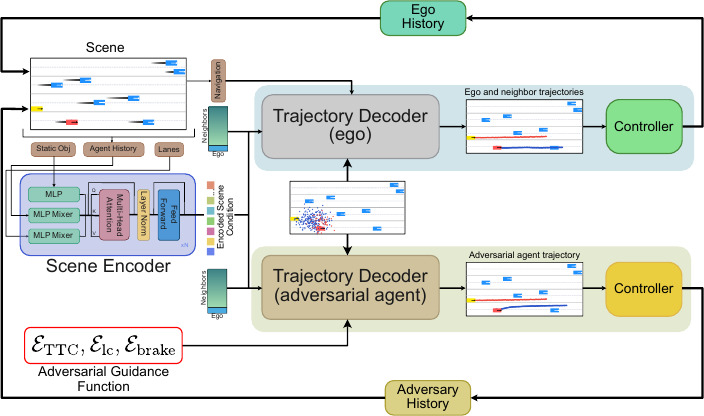 One Diffusion Model, Two Roles: Guided Trajectory Planning and Safety-Critical Scenario Generation in Closed-Loop SimulationIn European Conference on Computer Vision Workshops (ECCVW), 2026
-
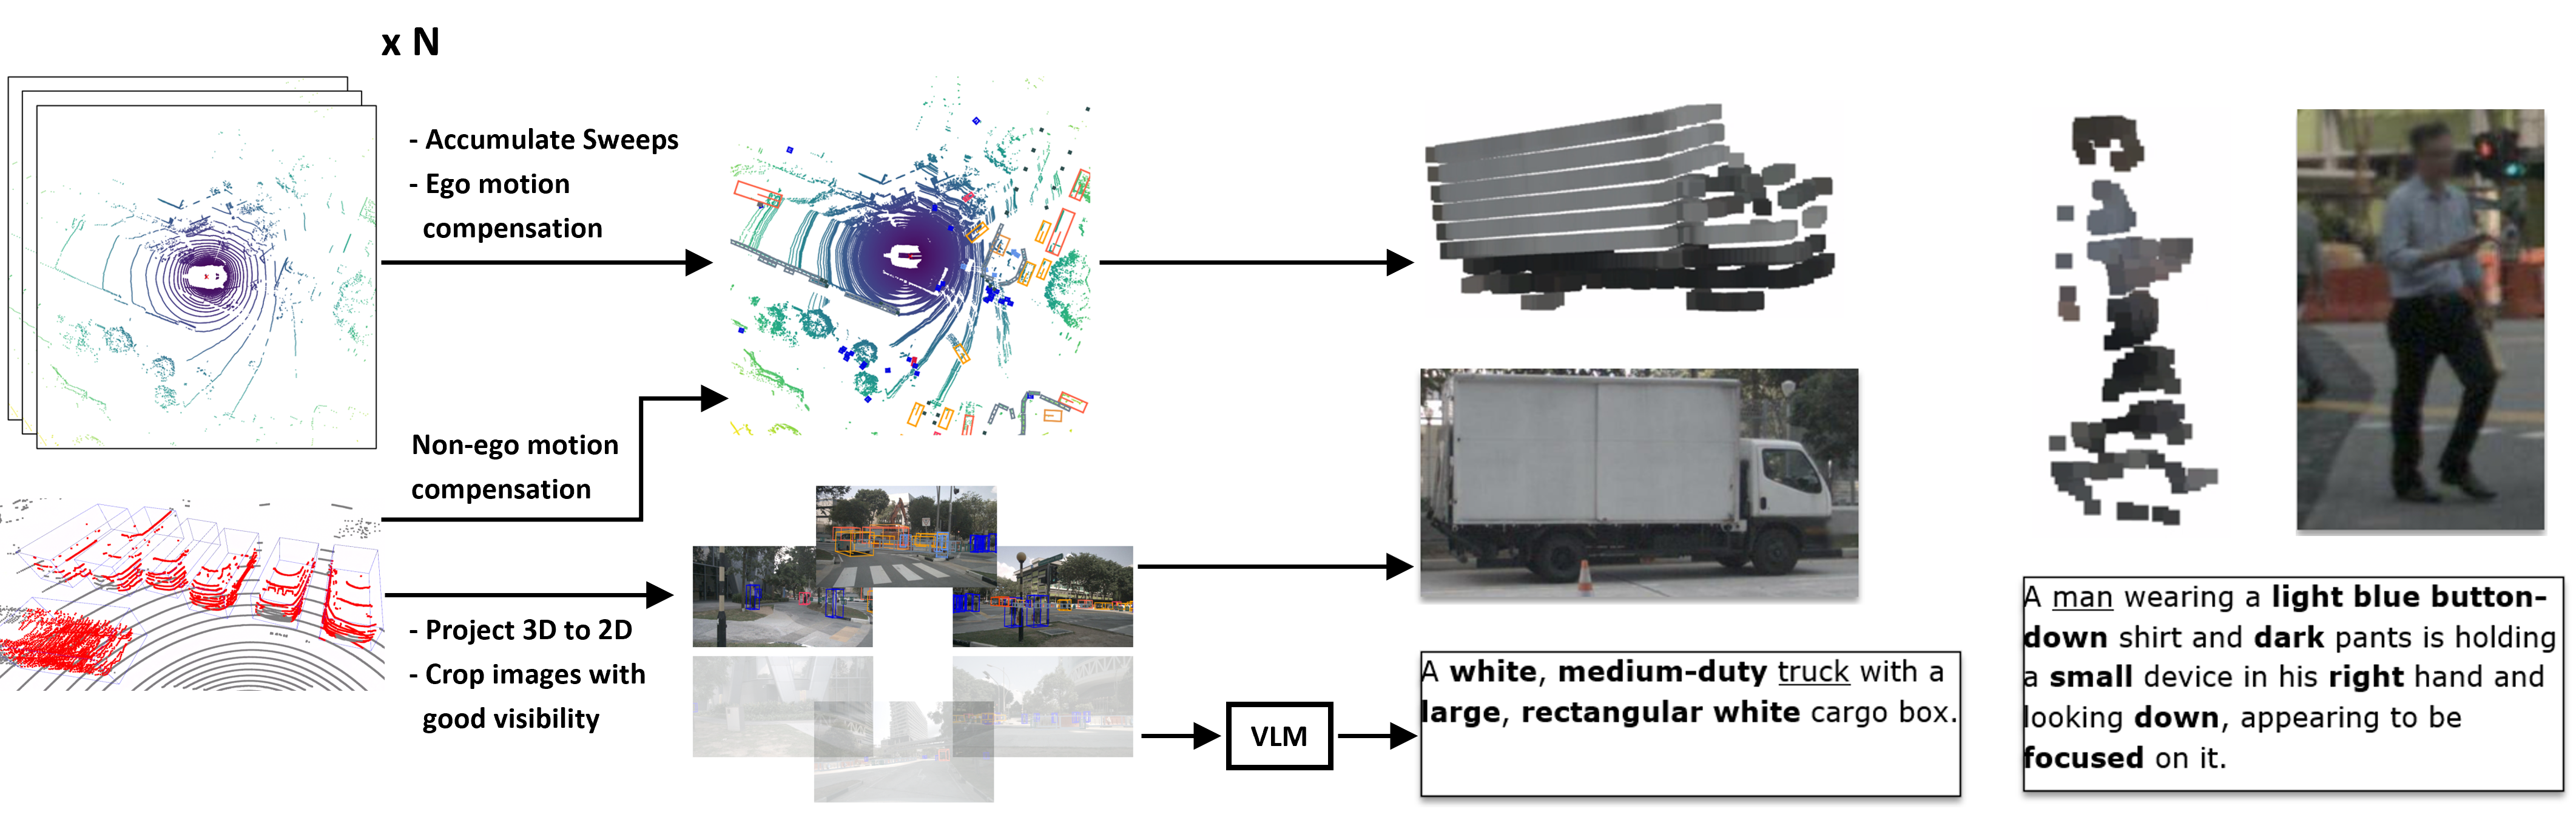 BlendCLIP: Bridging Synthetic and Real Domains for Zero-Shot 3D Object Classification with Multimodal PretrainingIn IEEE/CVF Winter Conference on Applications of Computer Vision (WACV), 2026
- HRIVirtual, Augmented, and Mixed Reality for Human-Robot Interaction Workshop (VAM-HRI)In Companion of the 2025 ACM/IEEE International Conference on Human-Robot Interaction, 2025
-
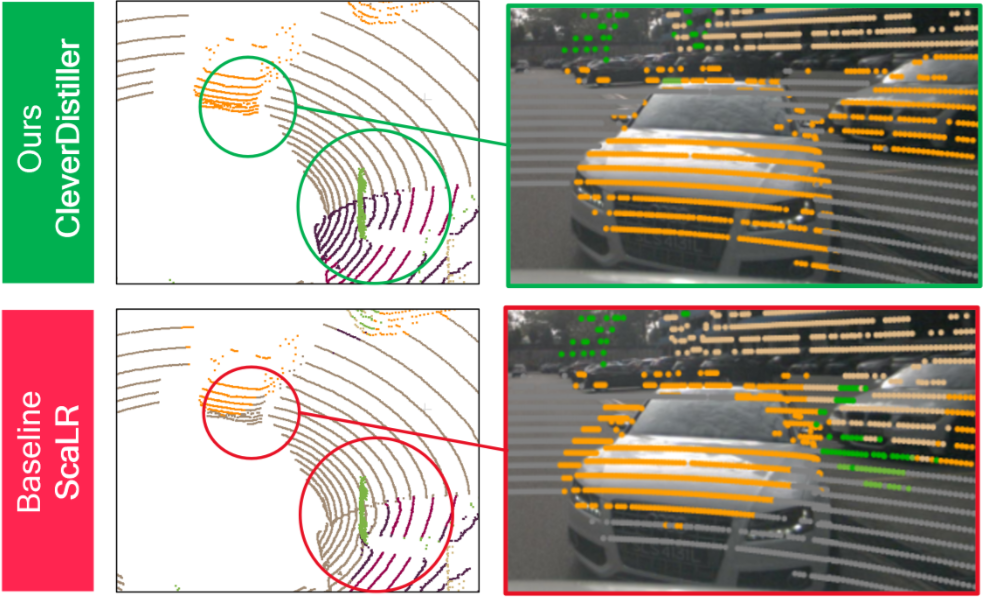 CleverDistiller: Simple and Spatially Consistent Cross-modal DistillationIn British Machine Vision Conference (BMVC), 2025Equal contribution: H. Govindarajan and M. K. Wozniak
- HRITake a Chance on Me: How Robot Performance and Risk Behaviour Affects Trust and Risk-takingIn Proceedings of the 2025 ACM/IEEE International Conference on Human-Robot Interaction, 2025
-
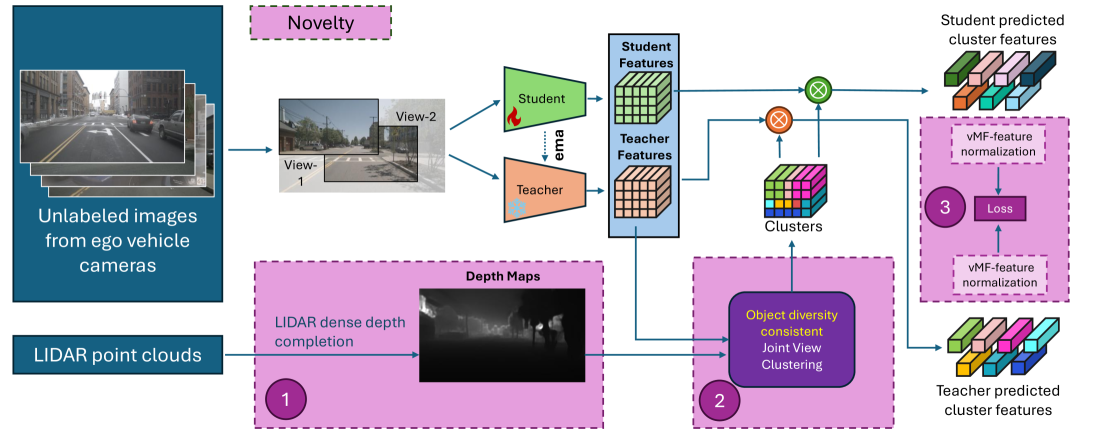 S3PT: Scene Semantics and Structure Guided Clustering to Boost Self-Supervised Pre-Training for Autonomous DrivingIn IEEE/CVF Winter Conference on Applications of Computer Vision (WACV), 2025Oral presentation
-
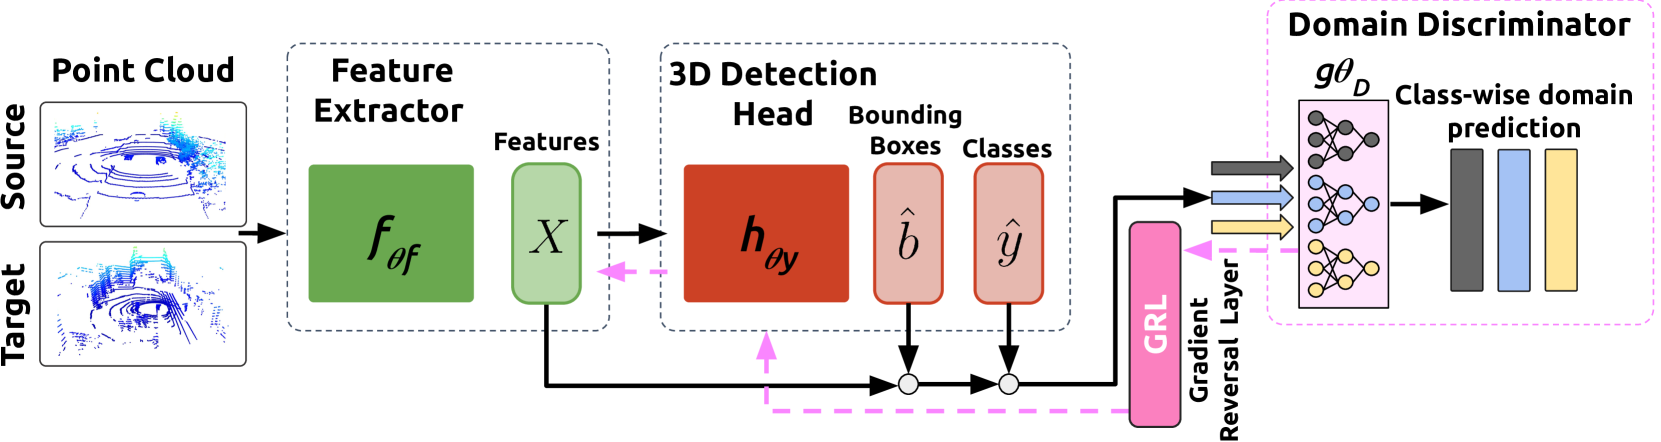 Uada3d: Unsupervised adversarial domain adaptation for 3d object detection with sparse lidar and large domain gapsIEEE Robotics and Automation Letters, 2024
-
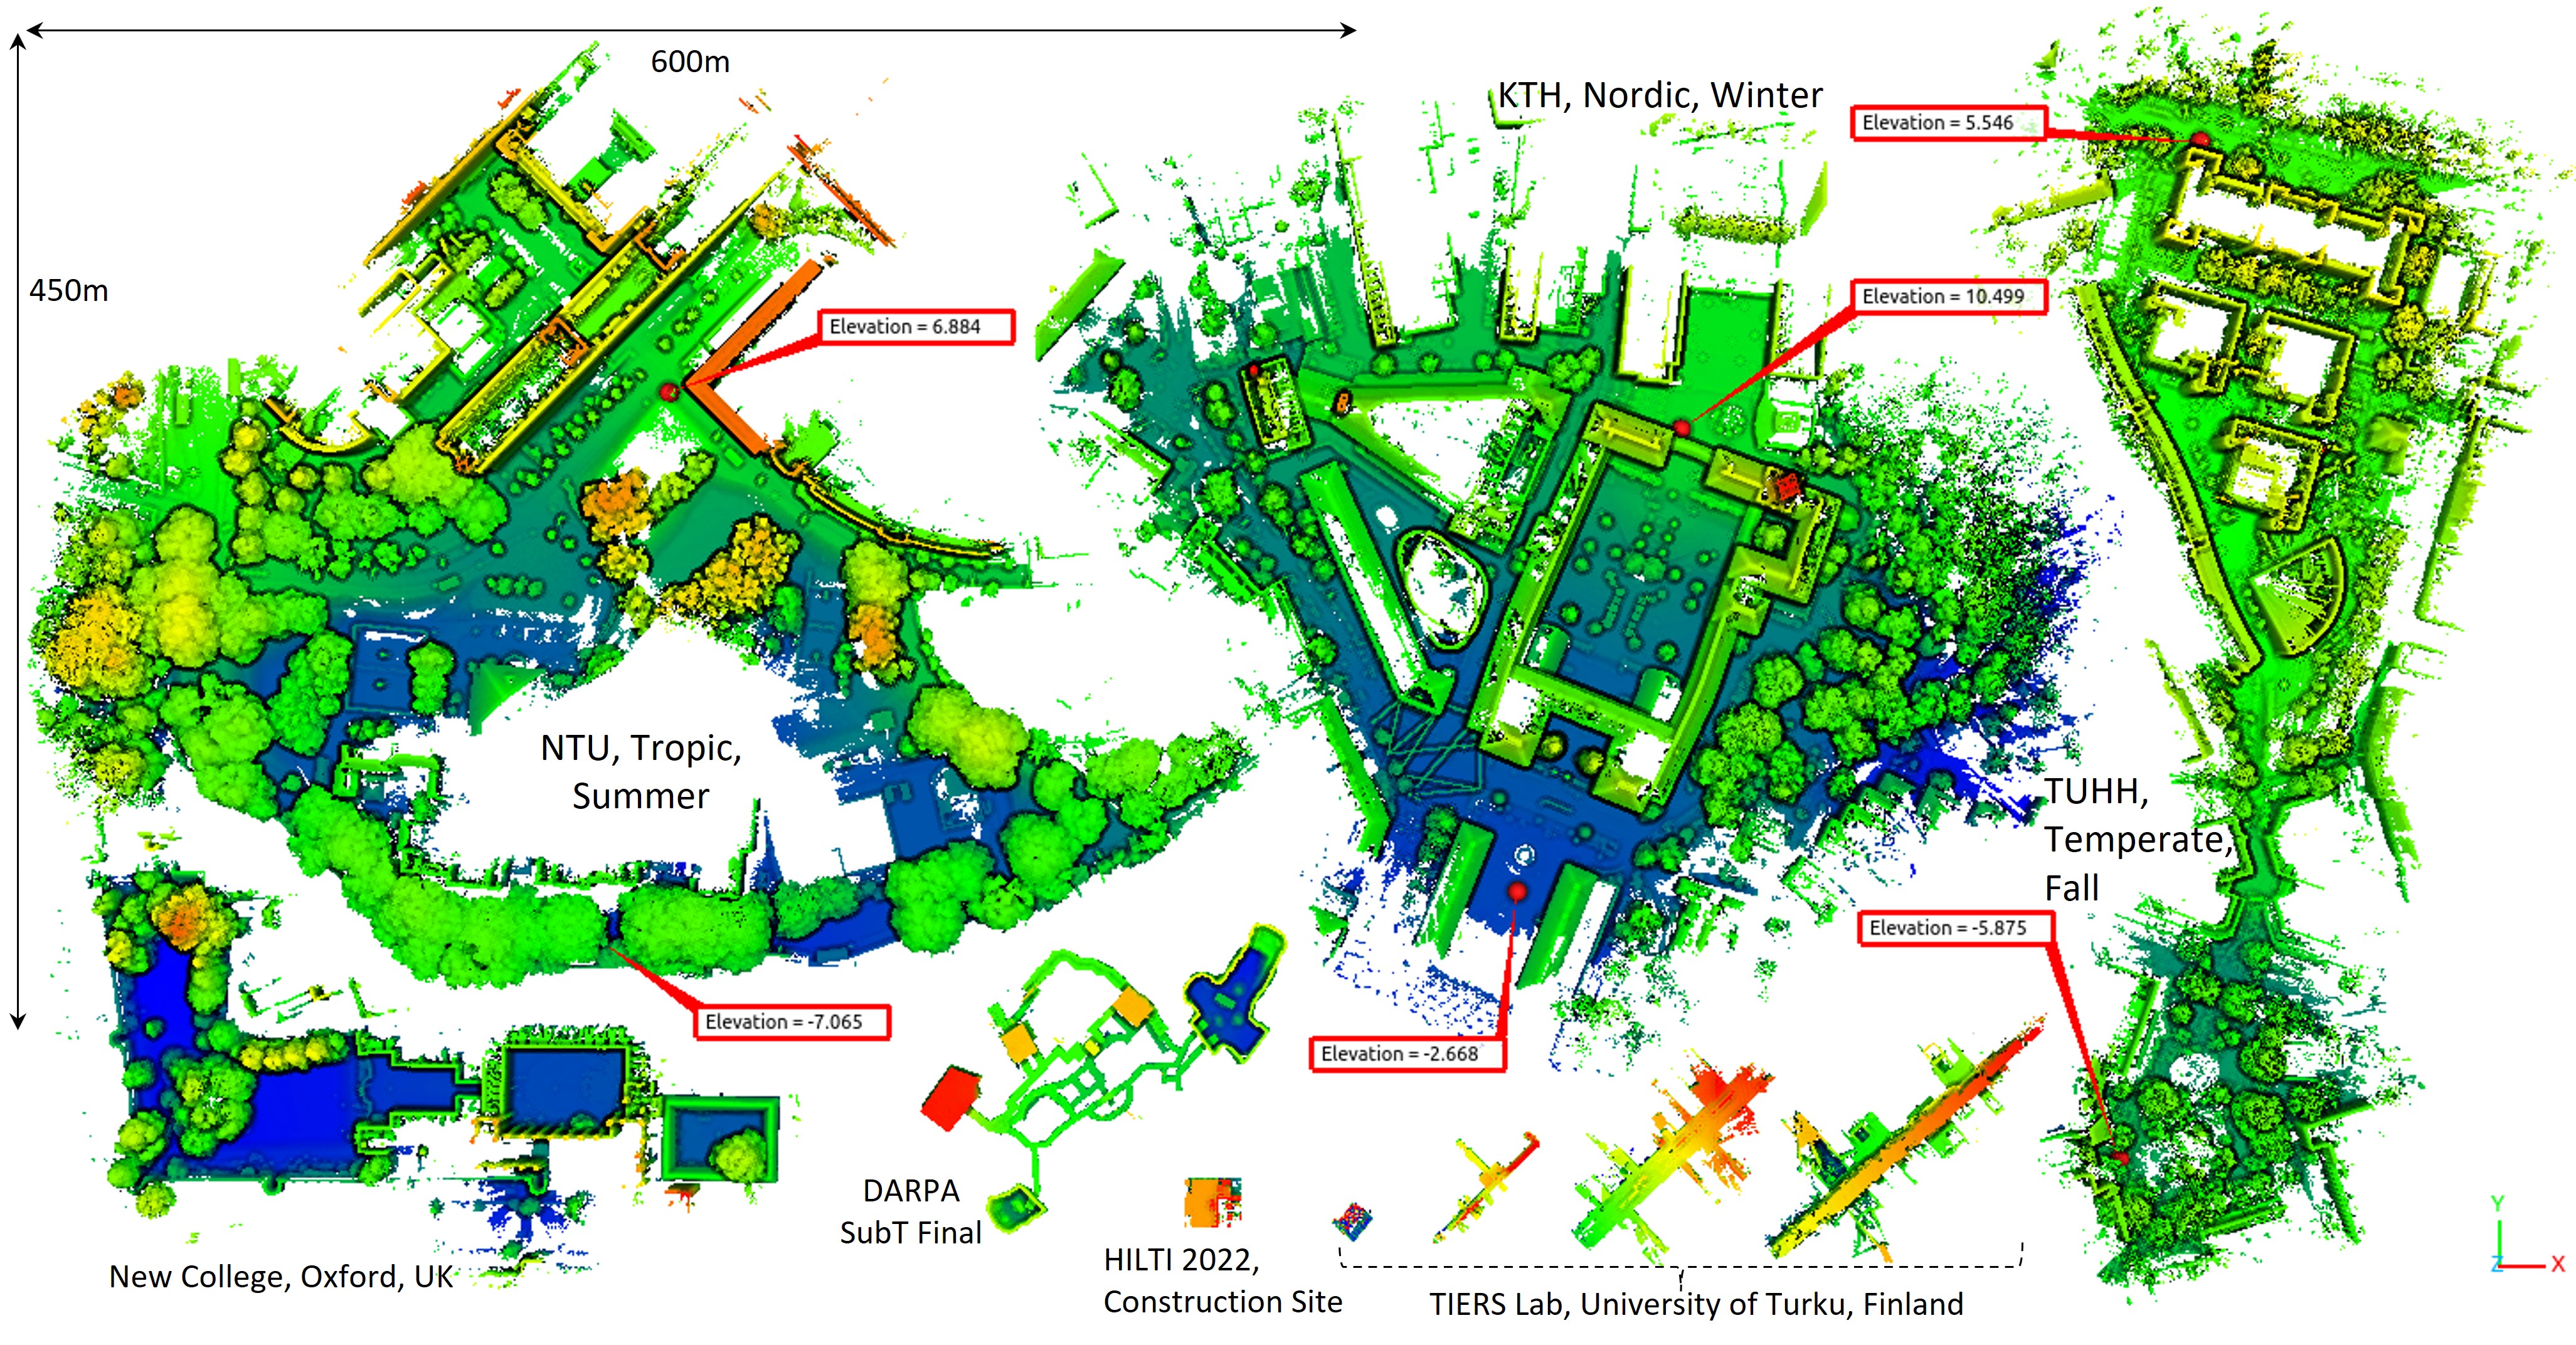 Mcd: Diverse large-scale multi-campus dataset for robot perceptionIn Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition, 2024
-
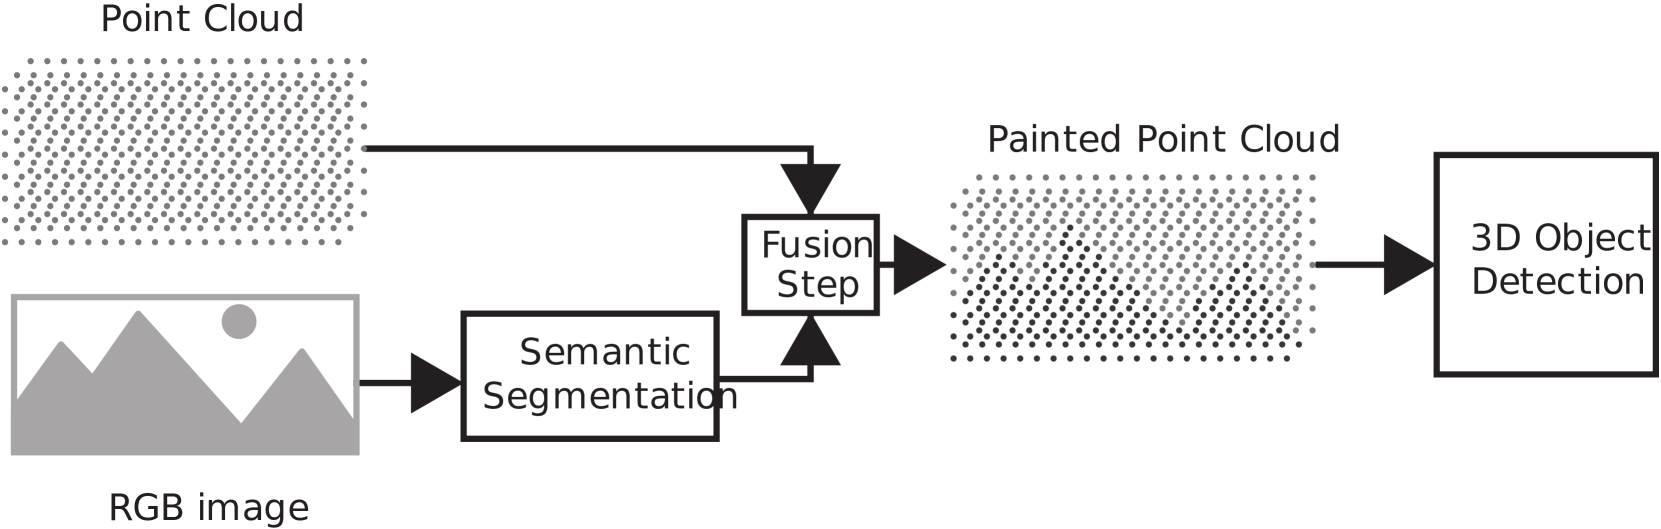 Towards a Robust Sensor Fusion Step for 3D Object Detection on Corrupted DataIEEE Robotics and Automation Letters, 2023
-
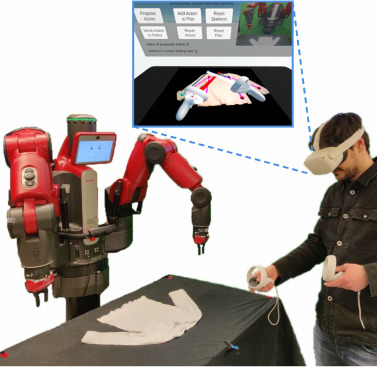 A Virtual Reality Framework for Human-Robot Collaboration in Cloth FoldingIn 2023 IEEE-RAS International Conference on Humanoid Robots (Humanoids), 2023
-
 Happily Error After: Framework Development and User Study for Correcting Robot Perception Errors in Virtual RealityIn IEEE International Symposium on Robot and Human Interactive Communication (RO-MAN), 2023
- ICARSCApplying 3D Object Detection from Self-Driving Cars to Mobile Robots: A Survey and ExperimentsIn 2023 IEEE International Conference on Autonomous Robot Systems and Competitions (ICARSC), 2023
-
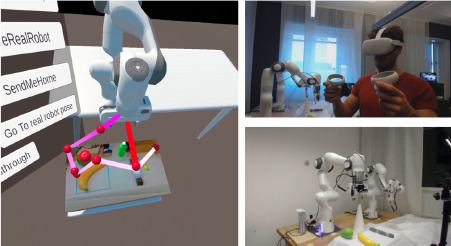 What you see is (not) what you get: A vr framework for correcting robot errorsIn Companion of the 2023 ACM/IEEE International Conference on Human-Robot Interaction, 2023
- HRIVirtual, augmented, and mixed reality for human-robot interaction (vam-hri)In Companion of the 2023 ACM/IEEE International Conference on Human-Robot Interaction, 2023
-
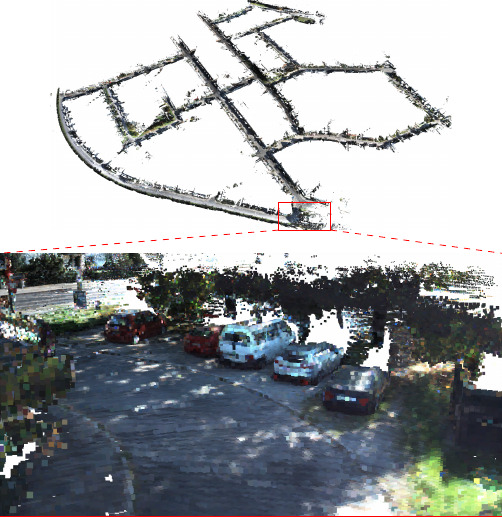 Semantic 3d grid maps for autonomous drivingIn 2022 IEEE 25th International Conference on Intelligent Transportation Systems (ITSC), 2022


