publications
publications by categories in reversed chronological order.
2026
- PhDLook Ma, No Labels: From Robust Perception to Self-Supervised Representation Learning for Autonomous DrivingKTH Royal Institute of Technology, 2026Doctoral thesis. Opponent: Andrei Bursuc (Valeo.ai)
-
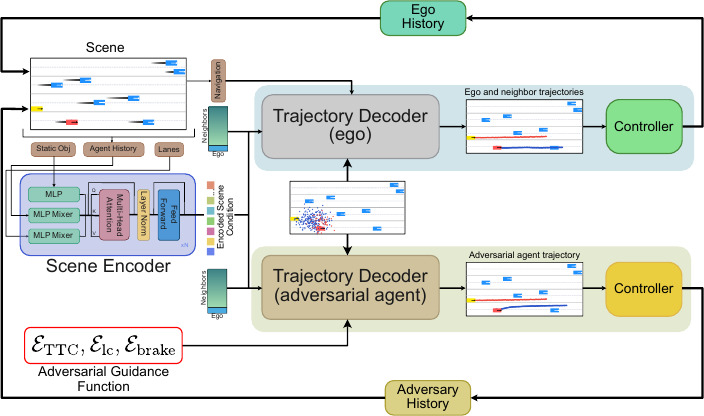 One Diffusion Model, Two Roles: Guided Trajectory Planning and Safety-Critical Scenario Generation in Closed-Loop SimulationIn European Conference on Computer Vision Workshops (ECCVW), 2026
-
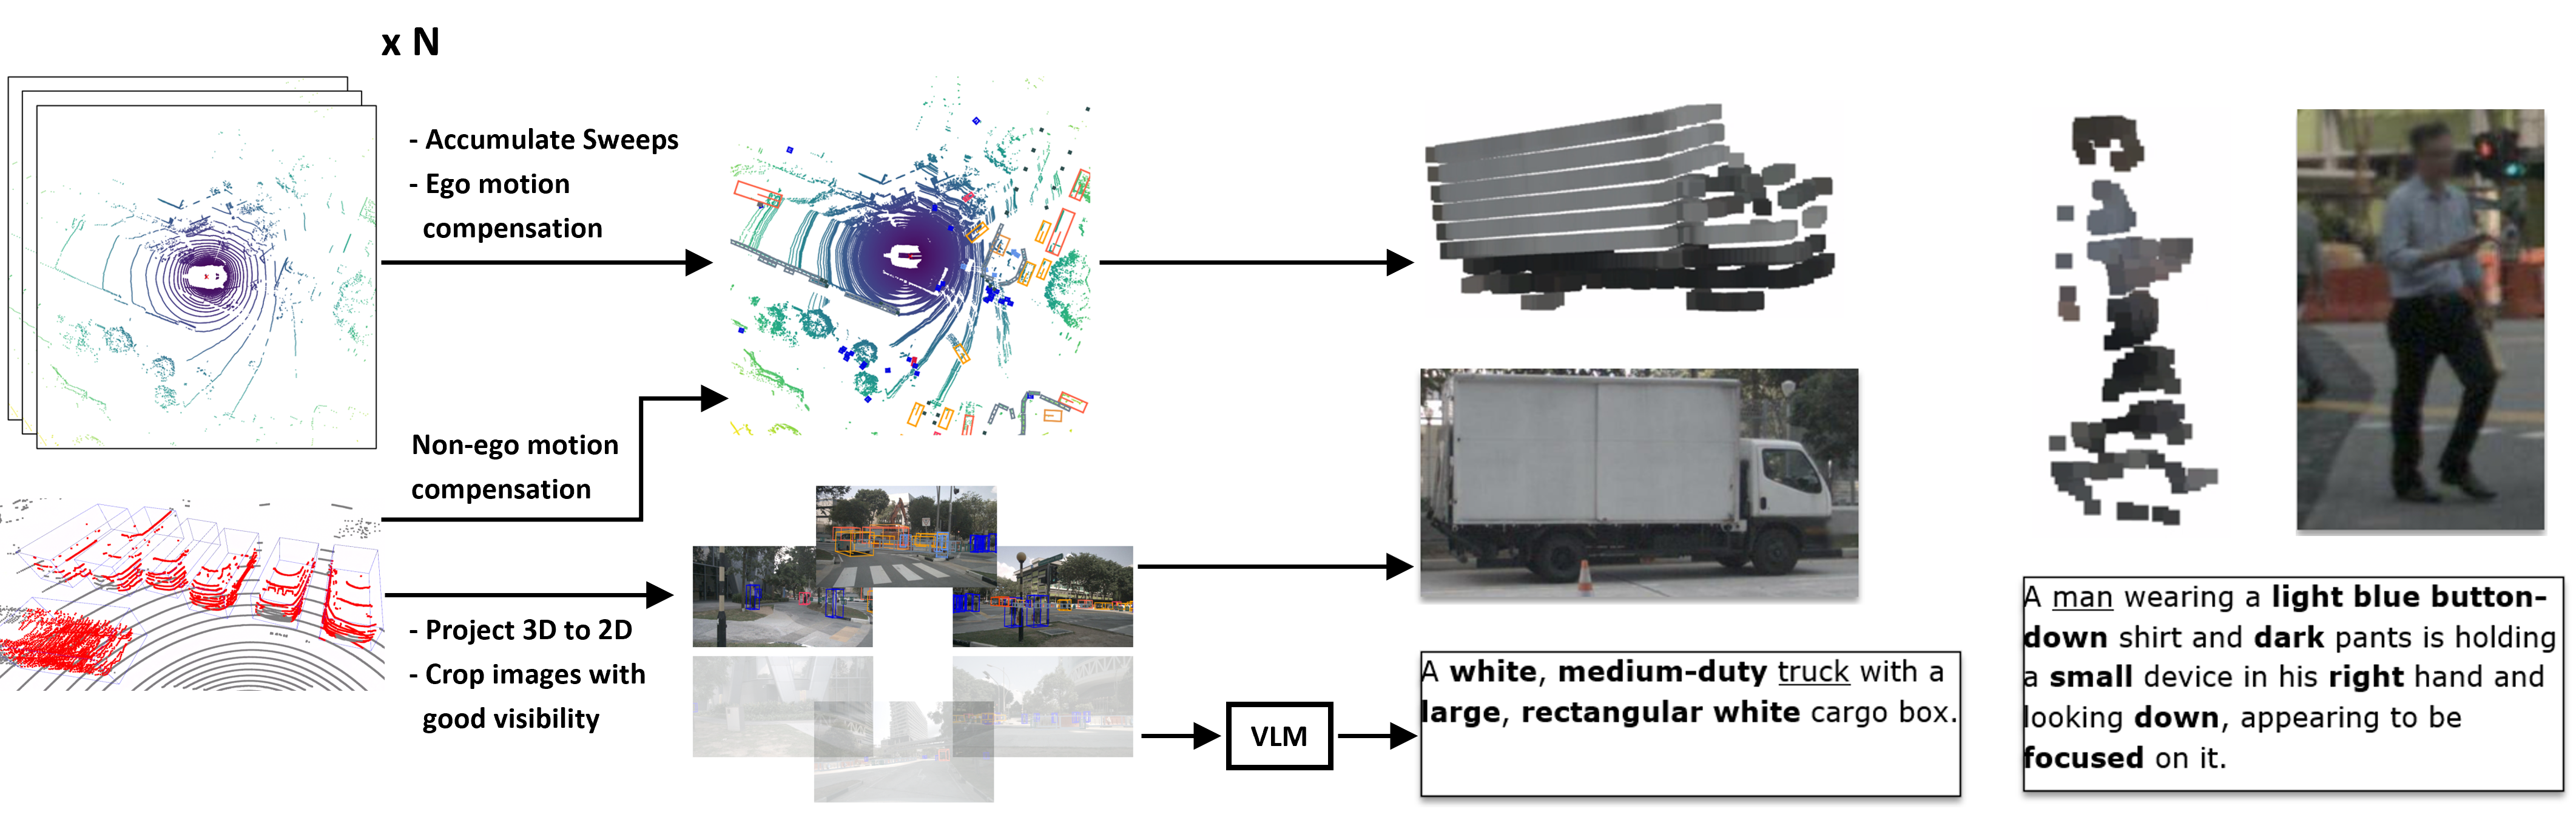 BlendCLIP: Bridging Synthetic and Real Domains for Zero-Shot 3D Object Classification with Multimodal PretrainingIn IEEE/CVF Winter Conference on Applications of Computer Vision (WACV), 2026


2025
- HRIVirtual, Augmented, and Mixed Reality for Human-Robot Interaction Workshop (VAM-HRI)In Companion of the 2025 ACM/IEEE International Conference on Human-Robot Interaction, 2025
-
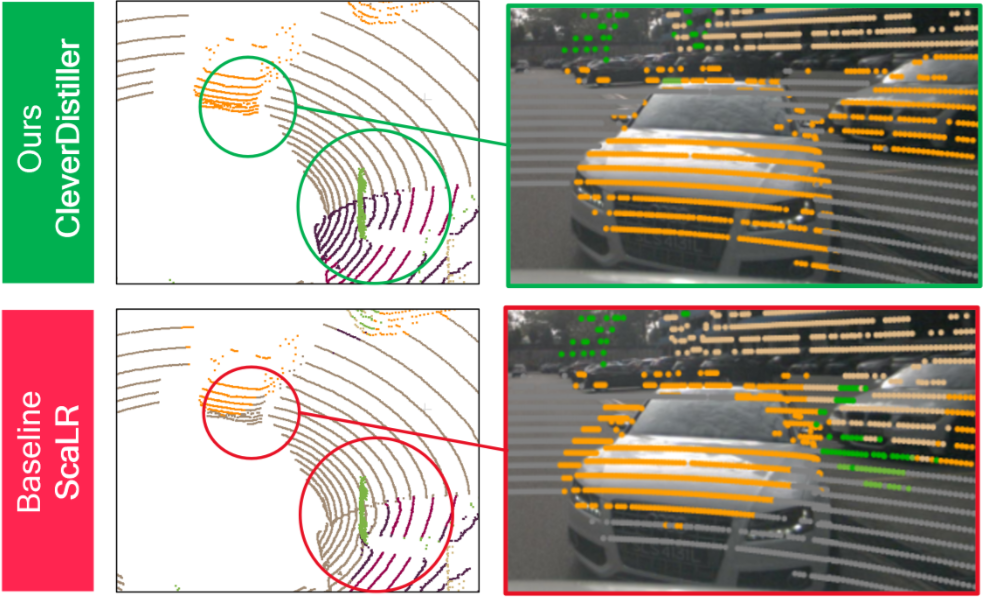 CleverDistiller: Simple and Spatially Consistent Cross-modal DistillationIn British Machine Vision Conference (BMVC), 2025Equal contribution: H. Govindarajan and M. K. Wozniak
- HRITake a Chance on Me: How Robot Performance and Risk Behaviour Affects Trust and Risk-takingIn Proceedings of the 2025 ACM/IEEE International Conference on Human-Robot Interaction, 2025
-
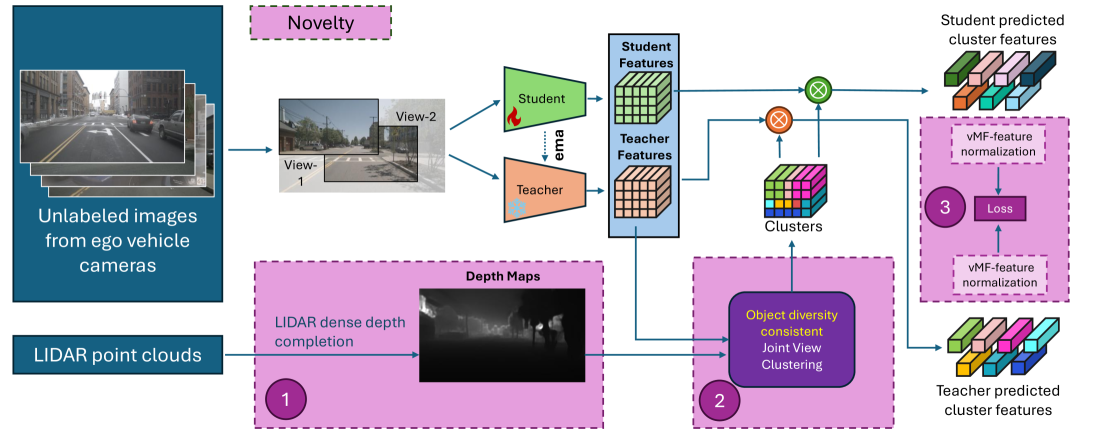 S3PT: Scene Semantics and Structure Guided Clustering to Boost Self-Supervised Pre-Training for Autonomous DrivingIn IEEE/CVF Winter Conference on Applications of Computer Vision (WACV), 2025Oral presentation


2024
- HRI-WQuest2ROS: An App to Facilitate Teleoperating RobotsIn 7th International Workshop on Virtual, Augmented, and Mixed-Reality for Human-Robot Interactions (VAM-HRI), 2024
- CVPRWSim-to-Real Adversarial Domain Adaptation for 3D Object DetectionIn IEEE/CVF Conference on Computer Vision and Pattern Recognition Workshops (CVPRW), 2024
- HRIEnhancing Robot Perception with Real-World HRIIn Companion of the 2024 ACM/IEEE International Conference on Human-Robot Interaction, 2024
- HRIVirtual, Augmented, and Mixed Reality for Human-Robot Interaction (VAM-HRI)In Companion of the 2024 ACM/IEEE International Conference on Human-Robot Interaction, 2024
-
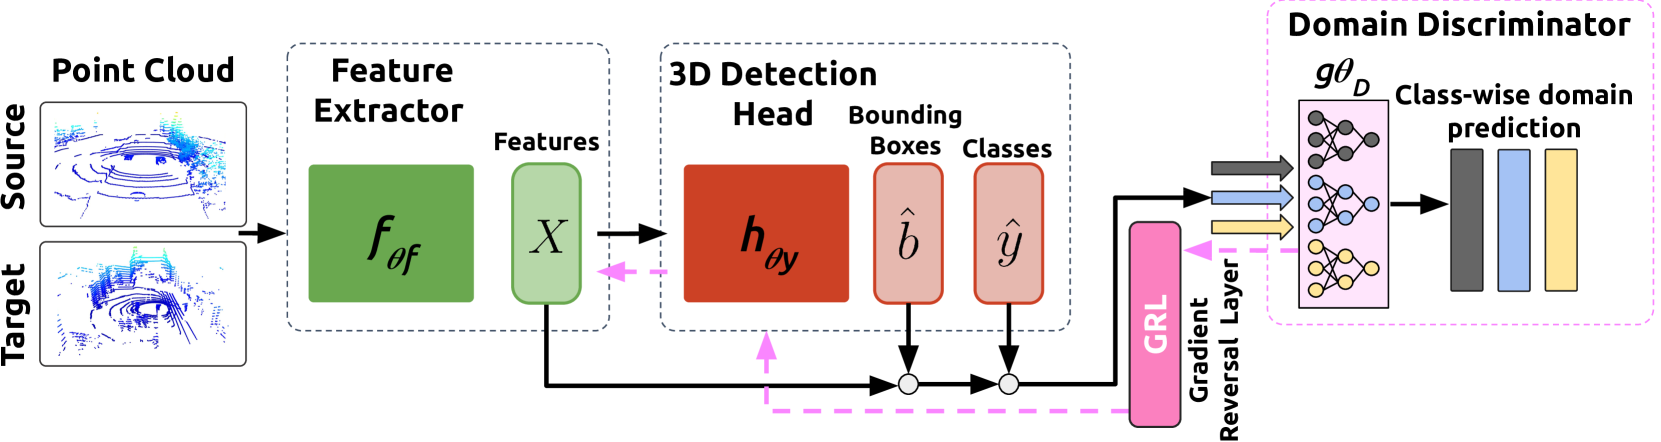 Uada3d: Unsupervised adversarial domain adaptation for 3d object detection with sparse lidar and large domain gapsIEEE Robotics and Automation Letters, 2024
-
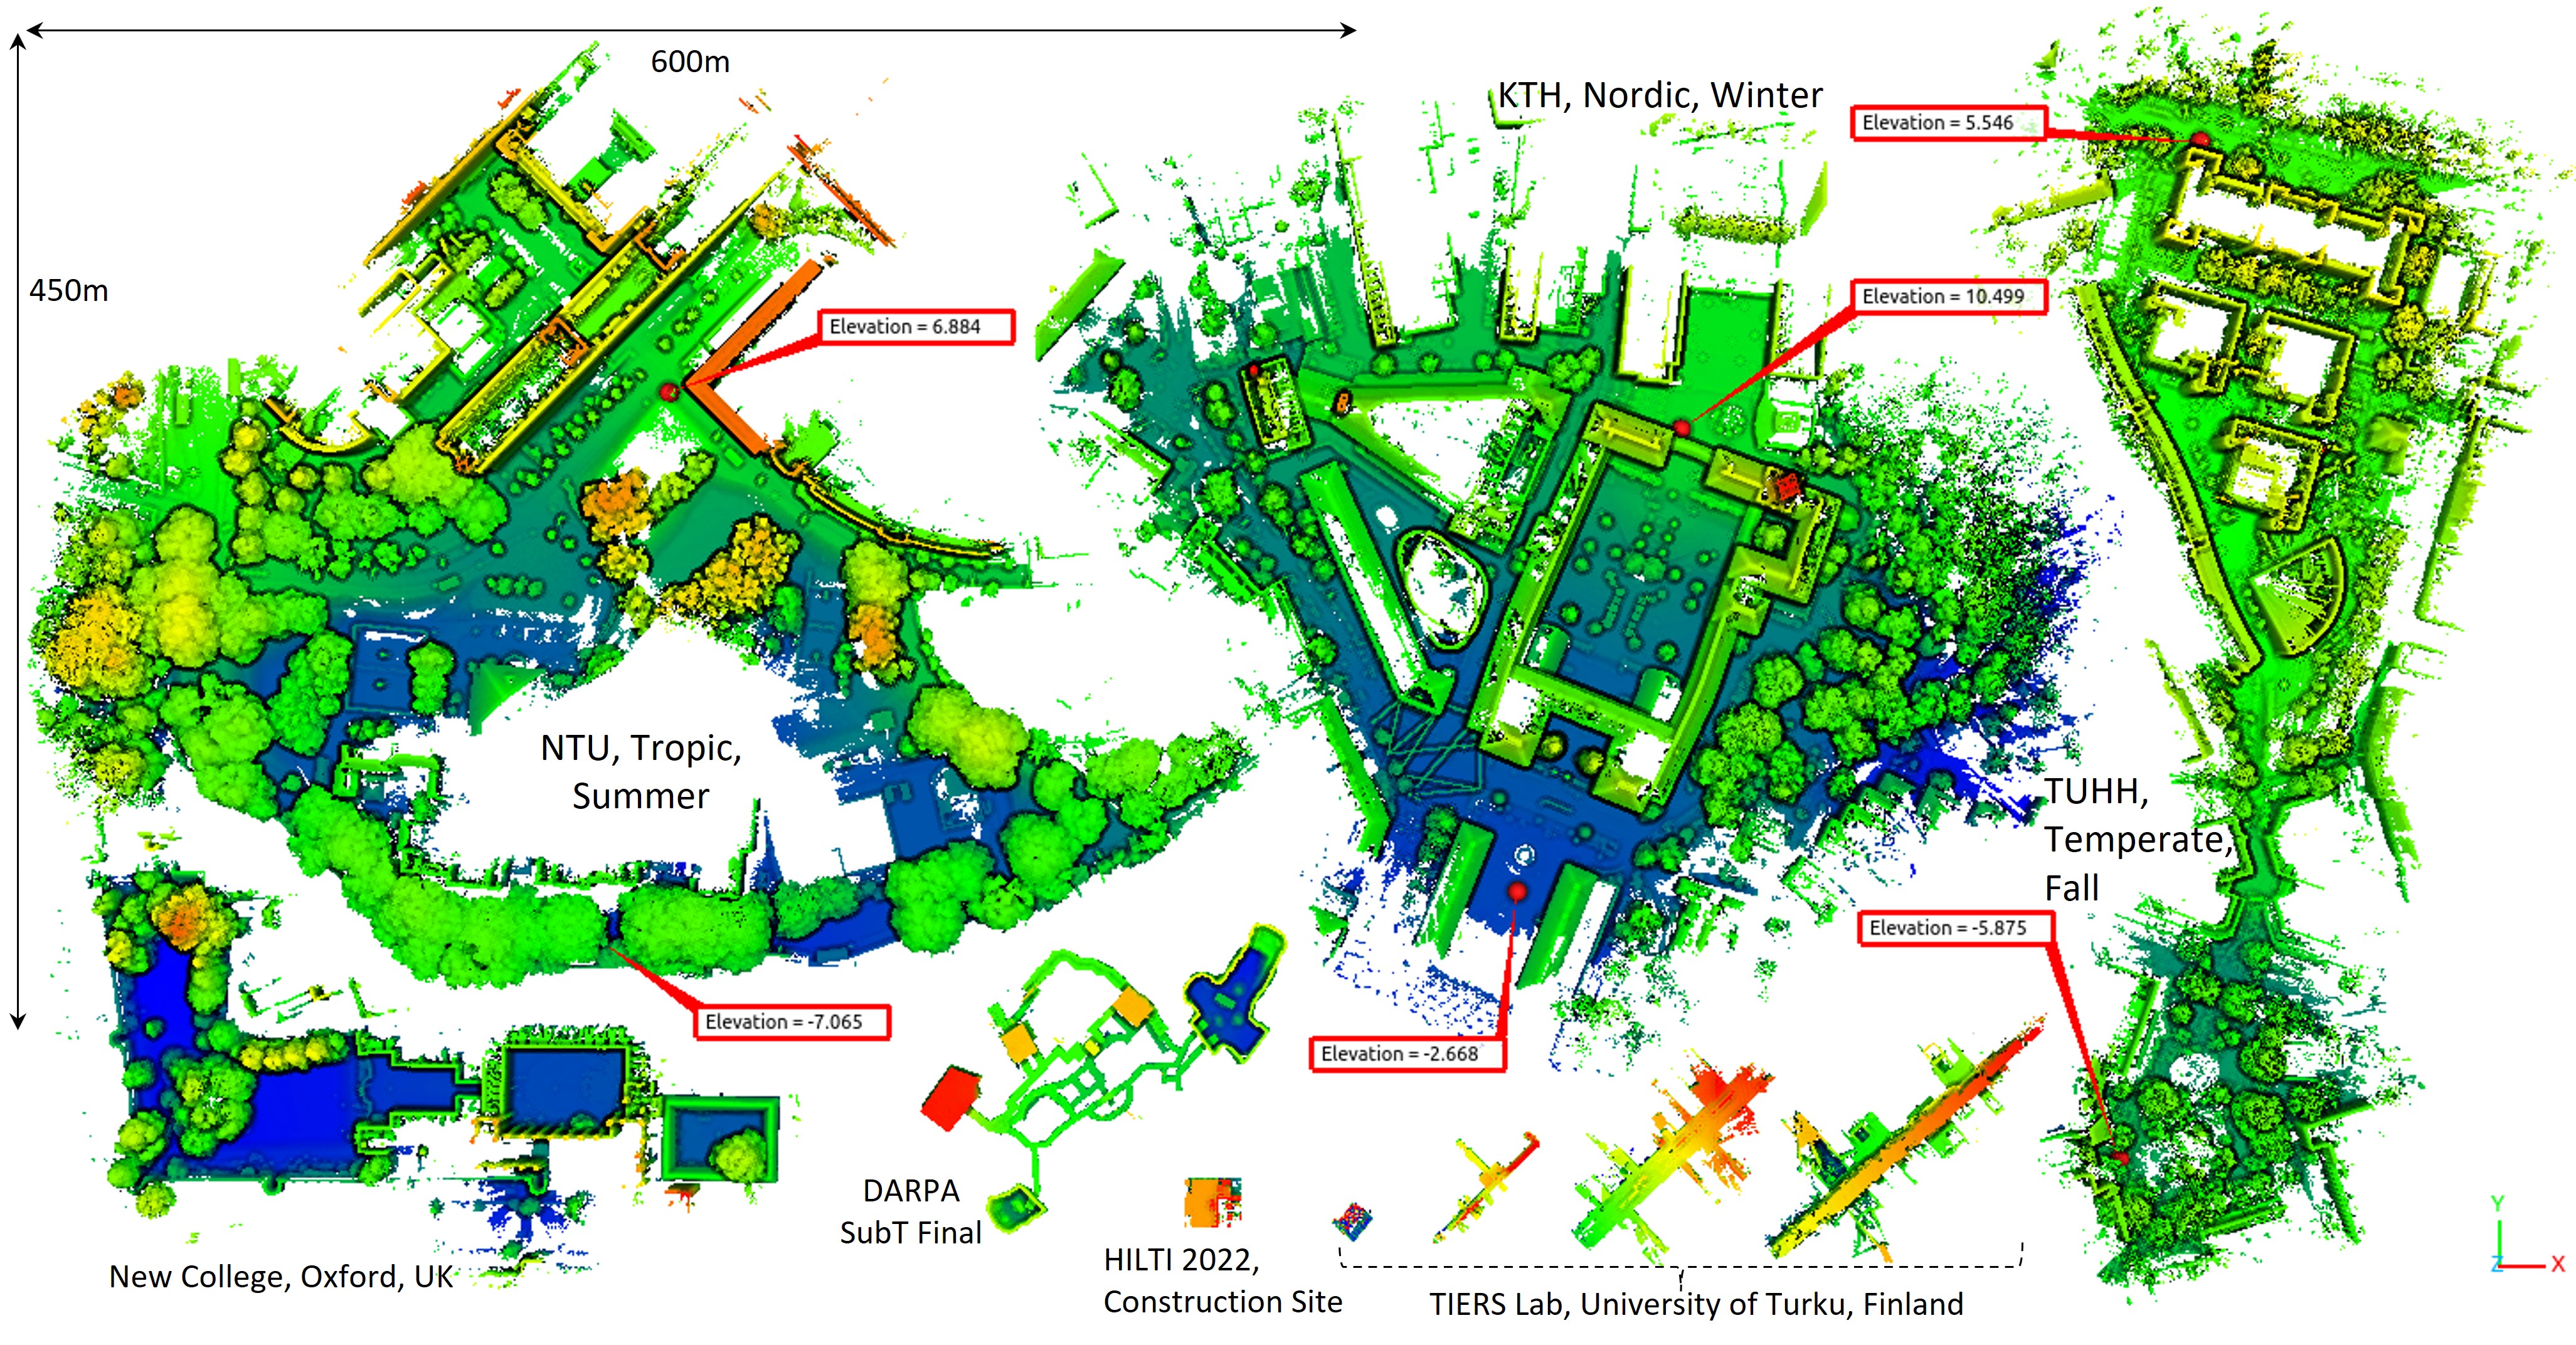 Mcd: Diverse large-scale multi-campus dataset for robot perceptionIn Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition, 2024


2023
-
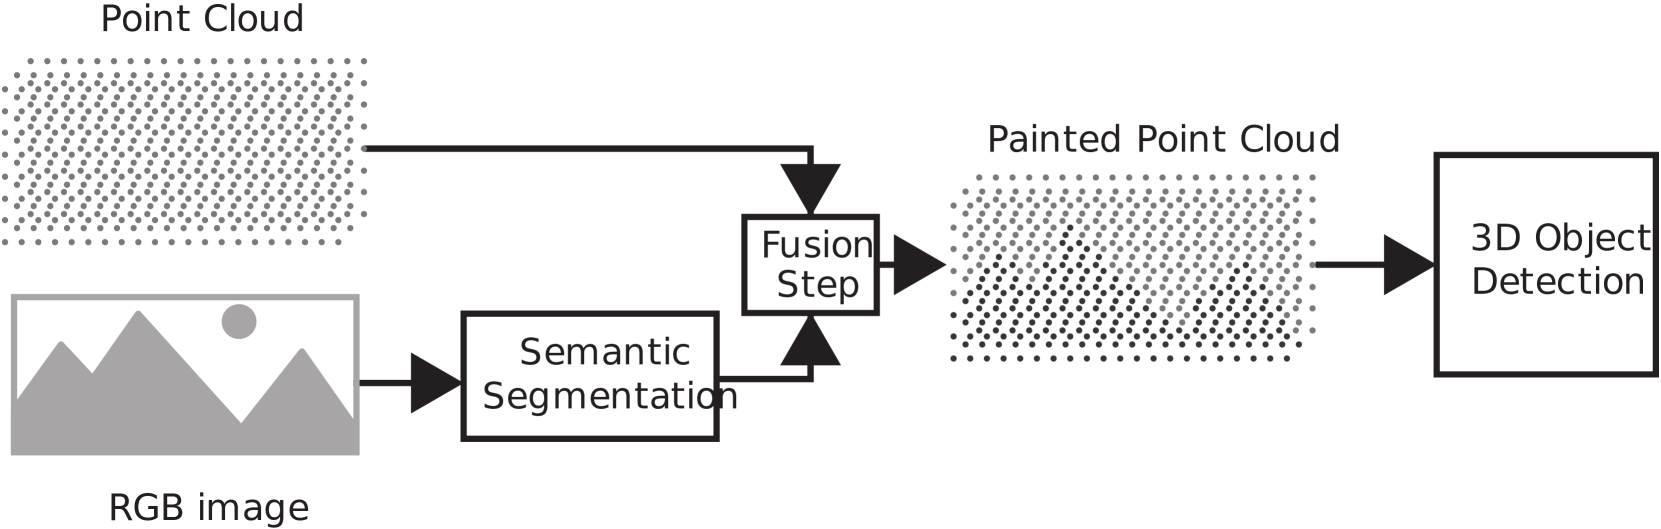 Towards a Robust Sensor Fusion Step for 3D Object Detection on Corrupted DataIEEE Robotics and Automation Letters, 2023
- BMCHow to use machine learning and fuzzy cognitive maps to test hypothetical scenarios in health behavior change interventions: a case study on fruit intakeBMC Public Health, 2023
-
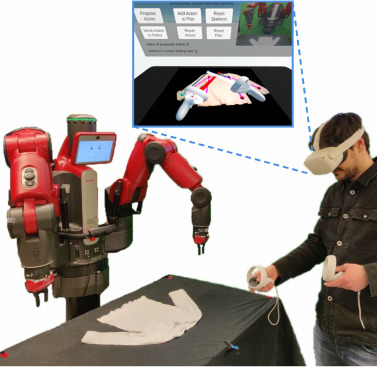 A Virtual Reality Framework for Human-Robot Collaboration in Cloth FoldingIn 2023 IEEE-RAS International Conference on Humanoid Robots (Humanoids), 2023
-
 Happily Error After: Framework Development and User Study for Correcting Robot Perception Errors in Virtual RealityIn IEEE International Symposium on Robot and Human Interactive Communication (RO-MAN), 2023
- ICARSCApplying 3D Object Detection from Self-Driving Cars to Mobile Robots: A Survey and ExperimentsIn 2023 IEEE International Conference on Autonomous Robot Systems and Competitions (ICARSC), 2023
-
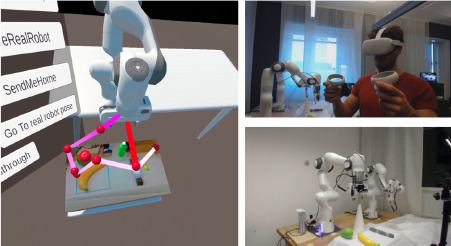 What you see is (not) what you get: A vr framework for correcting robot errorsIn Companion of the 2023 ACM/IEEE International Conference on Human-Robot Interaction, 2023
- HRIVirtual, augmented, and mixed reality for human-robot interaction (vam-hri)In Companion of the 2023 ACM/IEEE International Conference on Human-Robot Interaction, 2023


2022
-
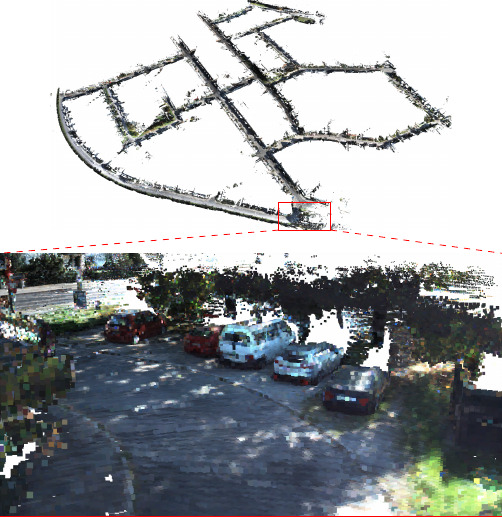 Semantic 3d grid maps for autonomous drivingIn 2022 IEEE 25th International Conference on Intelligent Transportation Systems (ITSC), 2022
- WSCA New Application of Machine Learning: Detecting Errors in Network SimulationsIn 2022 Winter Simulation Conference (WSC), 2022
- PeerJFCMpy: a python module for constructing and analyzing fuzzy cognitive mapsPeerJ Computer Science, 2022
- ICCSAutomatic generation of individual fuzzy cognitive maps from longitudinal dataIn International Conference on Computational Science, 2022

2021
- SIGSIMComparing implementations of cellular automata as images: A novel approach to verification by combining image processing and machine learningIn Proceedings of the 2021 ACM SIGSIM Conference on Principles of Advanced Discrete Simulation, 2021